Product Center
PRODUCT CENTER
BlueWhale-P1 Underwater Robot for Water Supply Pipe Inspection
This underwater robot is designed for inspecting small-diameter pipes, such as water supply lines. Its compact cylindrical shape allows it to navigate deep inside pipelines for inspection tasks, while the cable reel provides long-distance power and data transmission.
Key Features
- Small-Diameter Pipe Design: Sleek cylindrical form optimized for internal inspection of small-diameter pipes such as water supply lines, ensuring excellent maneuverability.
- Pressure-Rated Sealed Enclosure: Constructed from anodized aluminum alloy with a sealed, pressure-resistant design to withstand high-pressure water environments inside pipelines and ensure internal circuit safety.
- Multi-Propeller Vector Layout: Multiple thrusters distributed around the fuselage enable precise maneuvers such as forward/reverse motion, hovering, and attitude adjustment to adapt to complex conditions inside pipelines.
- HD Inspection Lens: Dual front-and-rear camera design captures real-time interior pipe footage to easily detect cracks, corrosion, blockages, and more.
- Rear cable interface: Works with the cable cart for long-distance power and signal transmission, unrestricted by operation range.
Use Cases
Internal inspection, hazard identification, and condition assessment for small-diameter pipelines in urban water supply networks and industrial water conveyance systems.
Core Parameters
| Chassis Structure | Single |
| Drive Type | Built-in power |
| Applicable Pipe Diameter Range | ≥ DN00 |
| Weight | (2.2 ± 0.1) kg |
| Maximum Single-Scan Detection Distance | 500 m |
| Maximum pressure rating | 1.6 MPa |
| Protection Rating | IP68 |
| Cornering ability | Single ≤ 90°; Continuous ≤ 270° |
| Localization Error (Odometry) | ≤0.5%(measurement distance) |
| Front Camera | 200 MP, 1080P, Wide-angle lens 100° |
| Rearview Camera | 30 megapixels, supports night vision |
| Lighting Configuration | Adjustable Brightness LED |
| Battery life | ≥ 8 h |
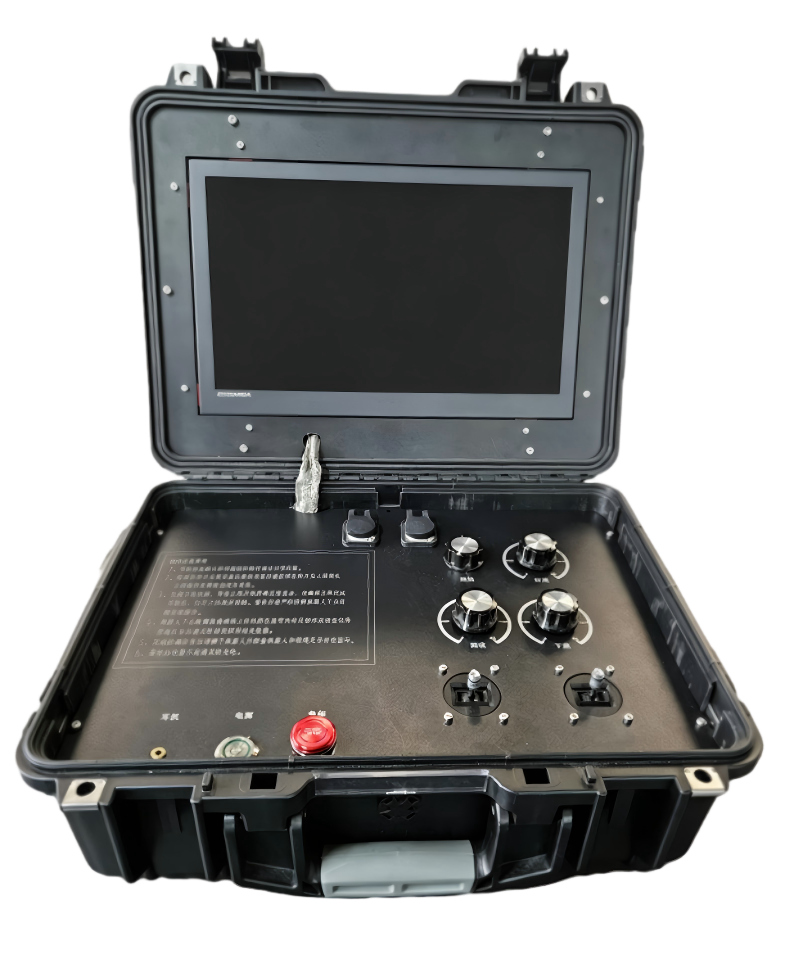
Underwater Robot Intelligent Control Box
The underwater pipeline inspection robot control box is the core control unit of the underwater pipeline inspection system. It receives operator commands to control the robot's movement, steering, camera adjustments, and lighting, while also receiving real-time data from the robot—including underwater pipeline images, video, depth, and pressure—and displaying, storing, and exporting this information.
Key Features
- Motion Control: Precisely control the underwater robot to move forward, backward, turn left, turn right, ascend, and descend.
- Light Control: Use the light knob to toggle the robot's fill light and adjust its brightness.
- Lowering Control: Use the lowering knob to start/stop and adjust the speed of zero-buoyancy cable deployment.
- Cycloid Control: Use the cycloid switch to start/stop the cycloid mechanism and automatically organize cables.
- Recovery Control: Use the recovery knob to start, stop, and adjust the speed of the zero-buoyancy cable retrieval.
Core Parameters
| Operating Voltage | DC 48V |
| Operating Current | ≤10A |
| Display Specifications | 14-inch HD touchscreen with 1920x1080 resolution, supporting multi-touch |
| Storage Capacity | 8G+128GB SSD, supports up to 1TB USB drive expansion |
| Enclosure Protection Rating | IP65: dust-tight, water-resistant |
| Operating Environment Temperature | -10℃~ 50℃ |
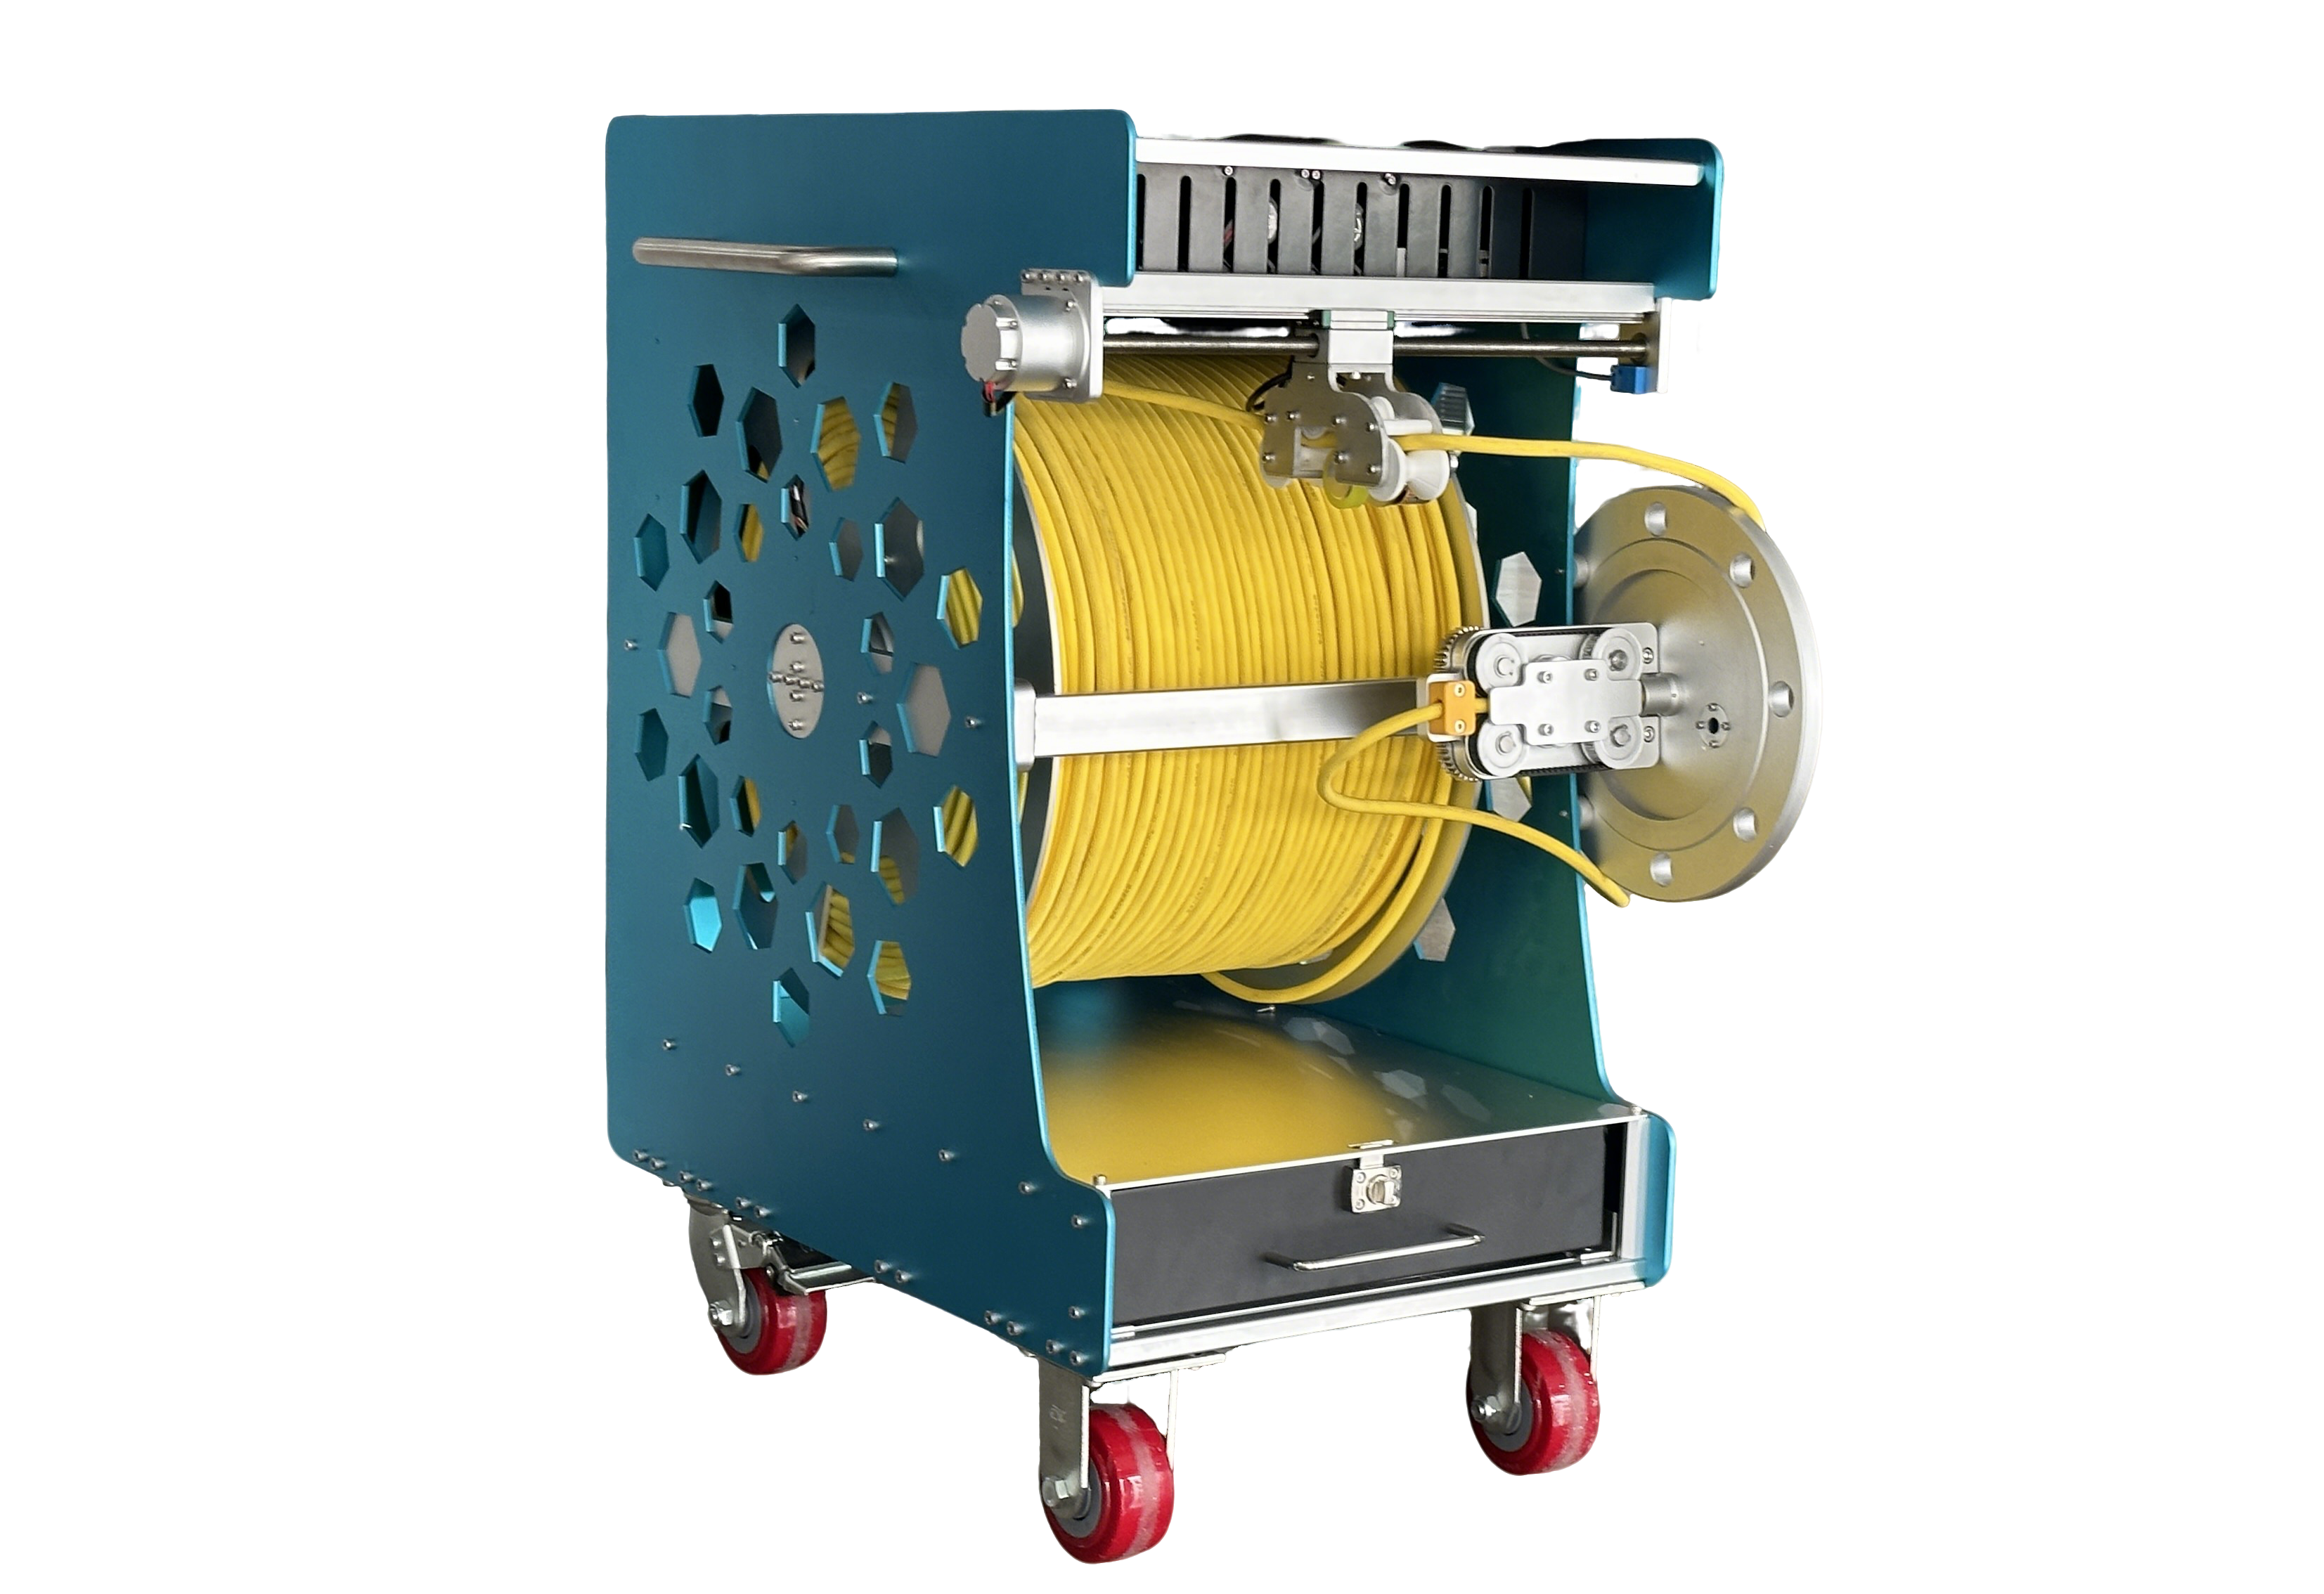
Underwater ROV Cable Reel
This product is a cable handling system designed specifically for underwater robots (ROV/AUV). Its mobile structure allows flexible deployment at docks, decks, and field sites to manage the deployment and retrieval of umbilical cables.
Key Features
- Large-capacity cable drum: The drum neatly winds multi-core umbilical cables with ample capacity to meet length requirements for deepwater and long-distance operations.
- Rotary Slip Ring Connector: Integrated rotary joint ensures continuous signal transmission and power supply during cable deployment and retrieval, preventing interruptions caused by rotation.
- All-metal CNC frame: The enclosure is machined from metal with anti-corrosion coating, built to withstand harsh environments like marine and humid conditions for long-lasting durability.
- Mobile caster base: Equipped with load-bearing casters and braking wheels at all four corners for easy on-site movement. Lock in place after positioning for secure operation.
Use Cases
Ideal for underwater robot inspection, recovery, scientific research, and subsea construction operations requiring long-distance umbilical cable deployment and retrieval.
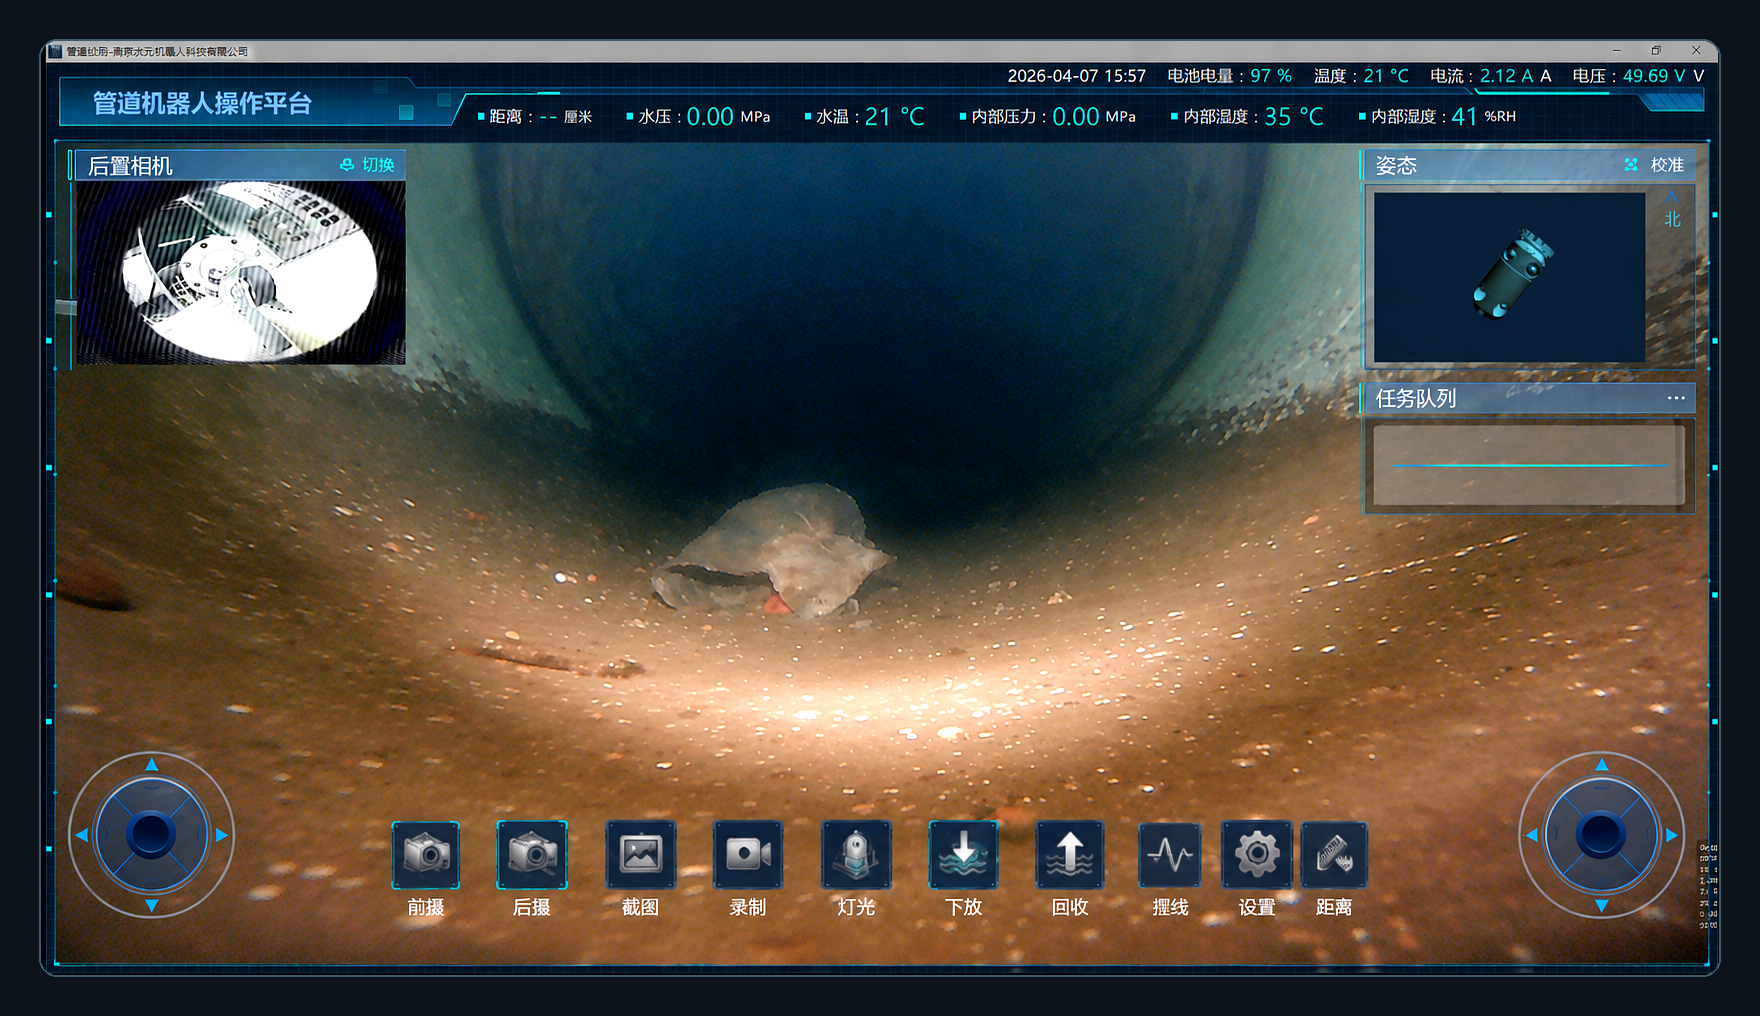
HydroAI Control Platform
The ROV host control software is an intelligent integrated management platform designed for pipeline inspection. It delivers video monitoring, robot operation, status monitoring, data recording, and analysis—providing users with efficient, precise, and reliable underwater inspection solutions.
Key Features
- Real-time Video Surveillance: High-definition image transmission to monitor internal pipe conditions in real time.
- Smart Robot Control: Supports motion control, posture adjustment, and auxiliary operations
- Multi-parameter real-time monitoring: Collects operational data such as water pressure, temperature, system pressure, and electrical parameters.
- Data Management & Analysis: Automatically record, store, and replay test data
- System Self-Check and Calibration: Ensures stable operation and enhances job reliability.